Vassil Atanassov
Hey! I am a third year PhD (DPhil) student in Robotics with the Dynamic Robot Systems group at the Oxford Robotics Institute, University of Oxford. My main interests are in legged robot locomotion and loco-manipulation and I'm working under the supervision of Prof. Ioannis Havoutis.
Previously, I graduated from the University of Glasgow with a BEng Mechanical Engineering in 2017, and from the Delft University of Technology with an MSc Robotics in 2023. My Master's thesis was on Curriculum-based DRL for agile jumping in quadruped robots under the supervision of Prof. Cosimo Della Santina.
CV
Github
Google Scholar
vassilatanassov at robots dot ox dot ac dot uk
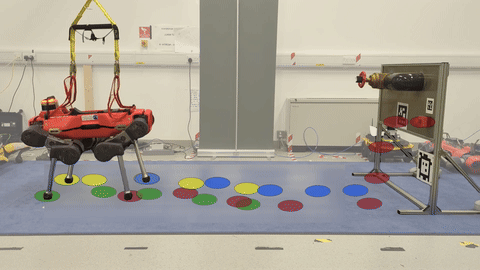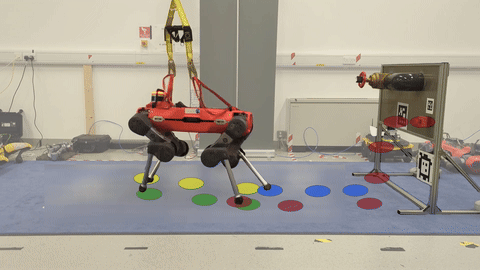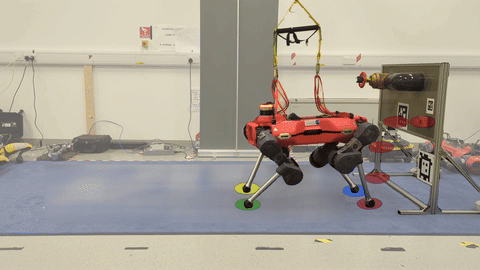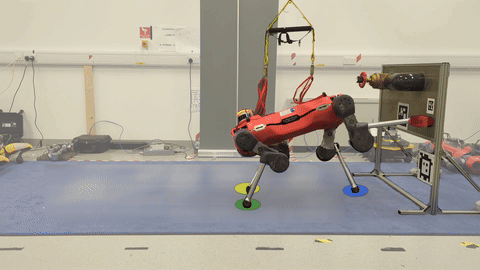
Learning a generalist contact-conditioned policy for robot locomotion and manipulation.
Paper Link Project Page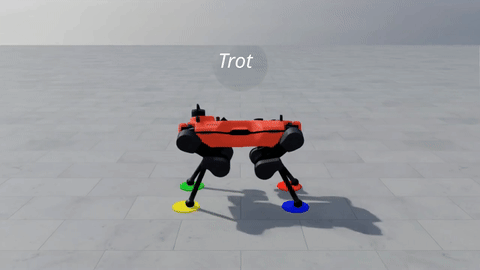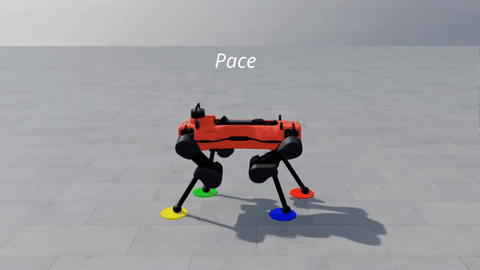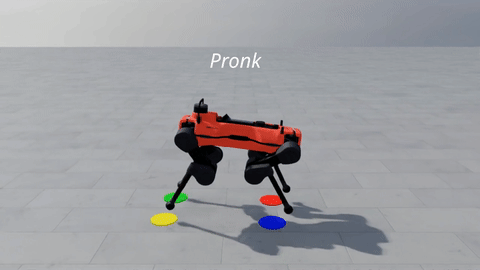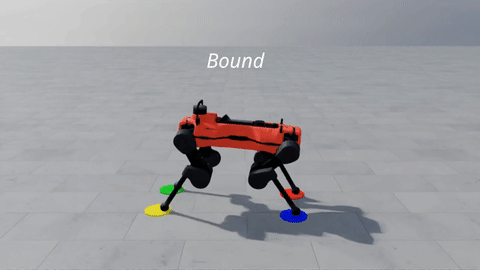
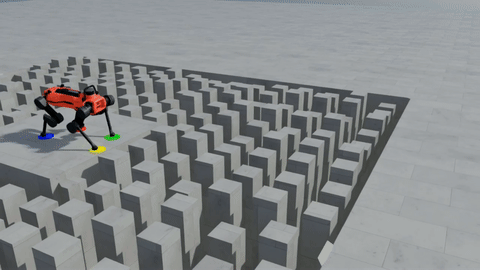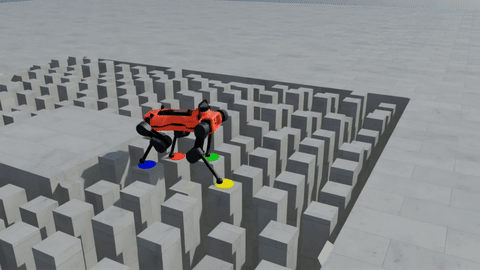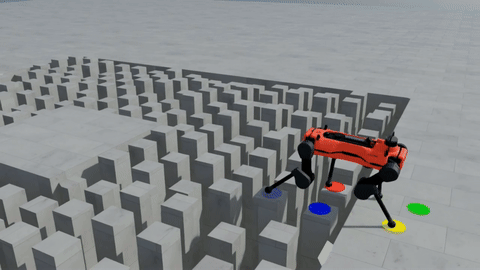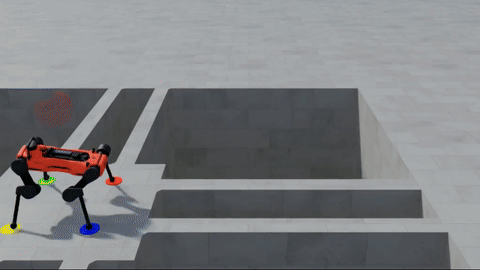
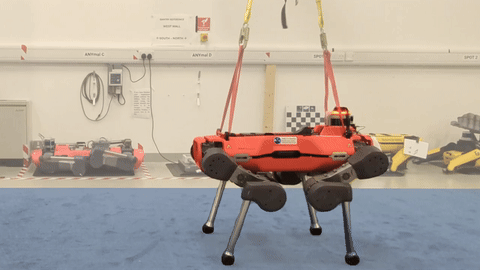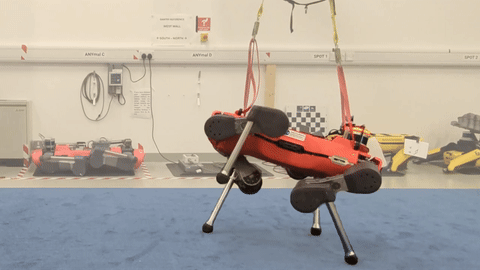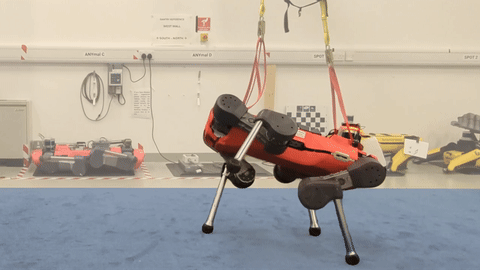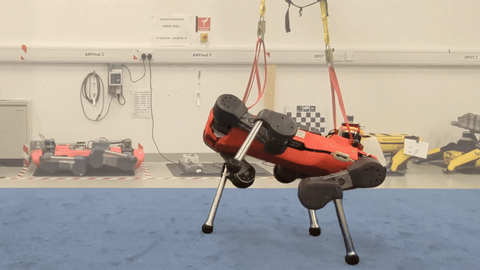
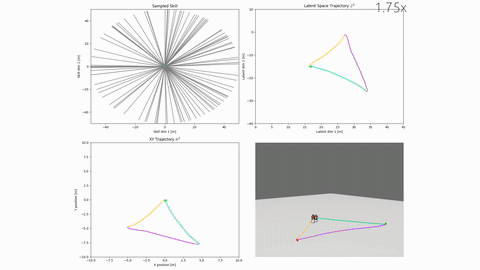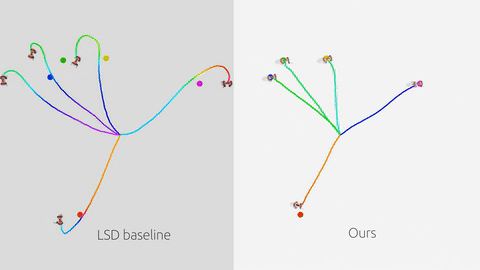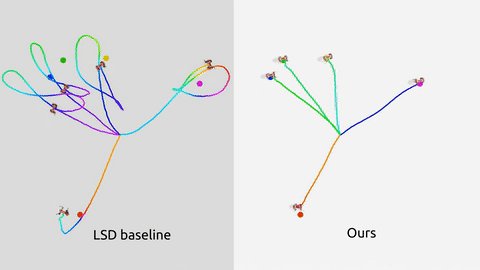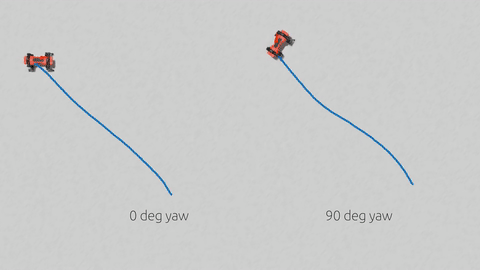
Learning legged locomotive behaviours with unsupervised skill discovery and with no task rewards.
Paper Link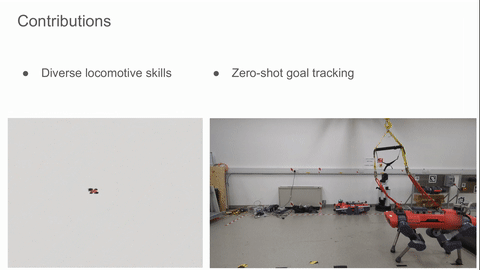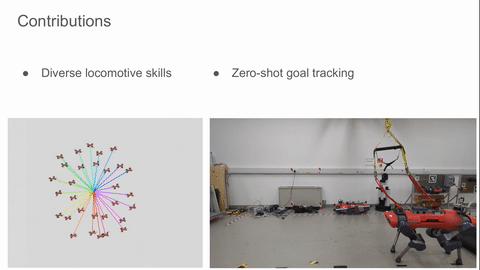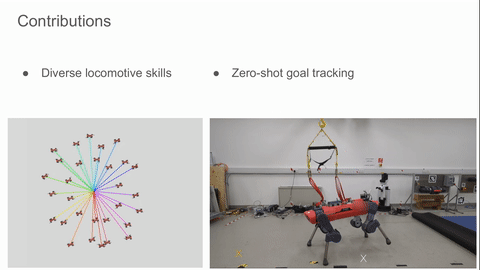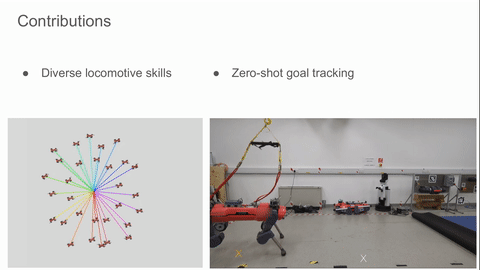
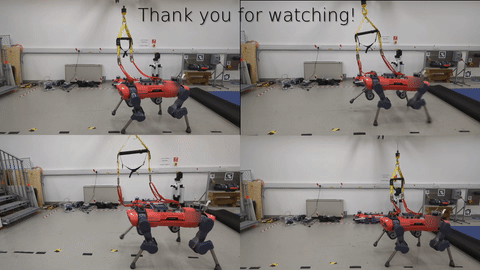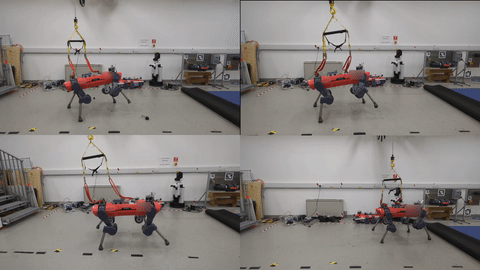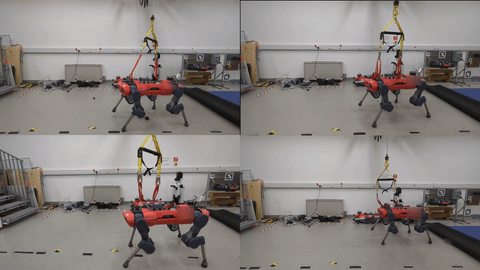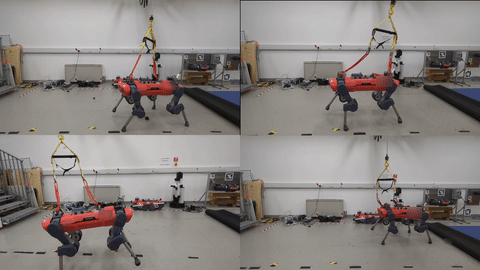
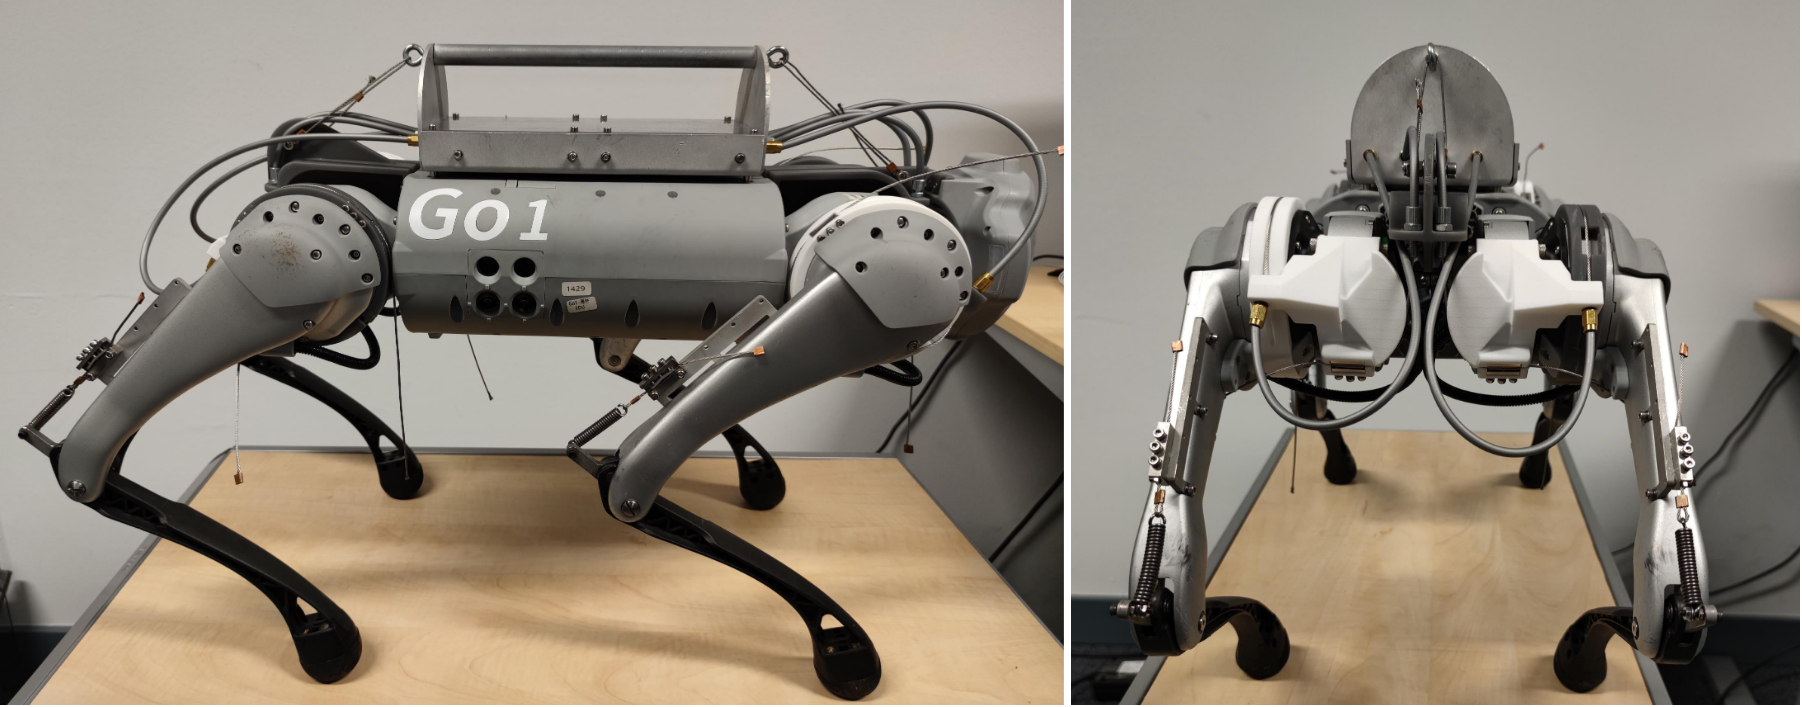
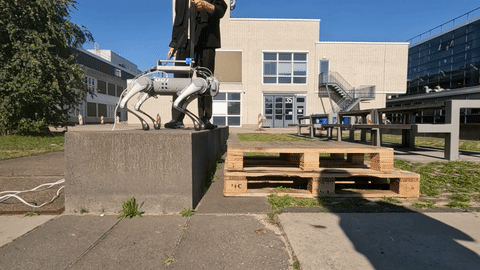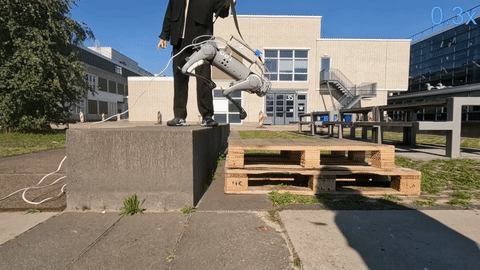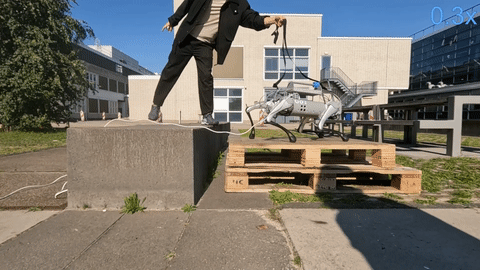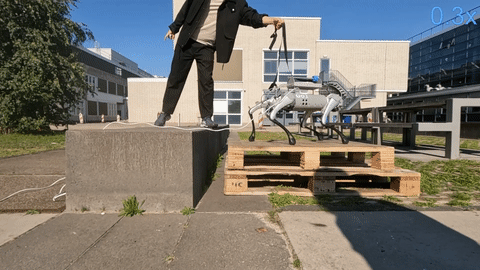
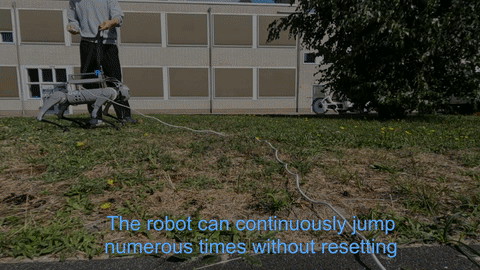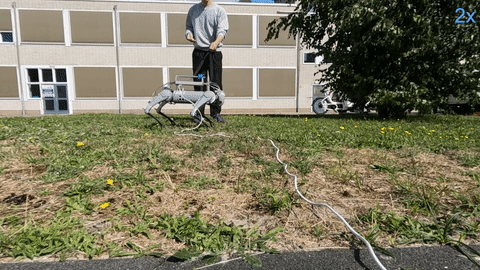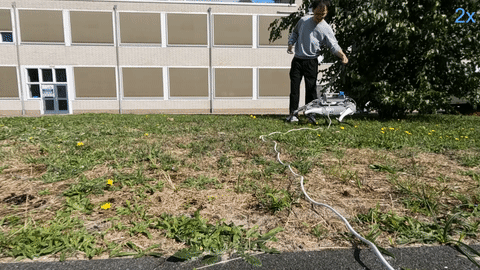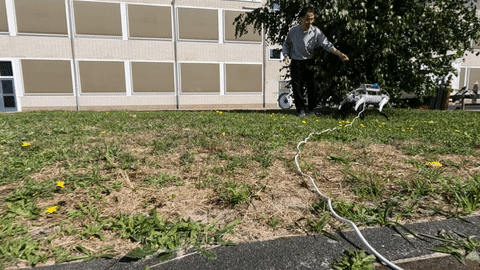
Agile quadruped jumping through curriculum-based DRL.
Paper Link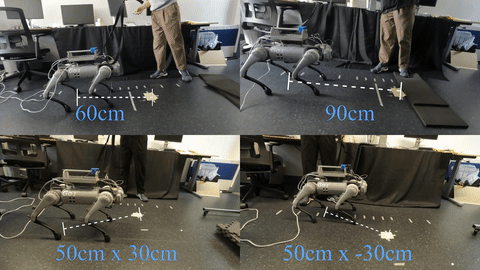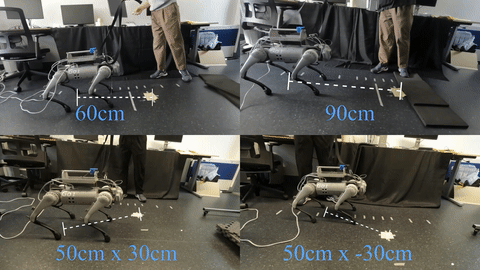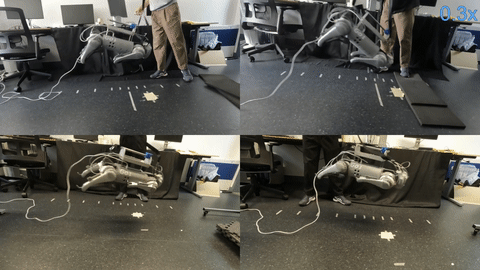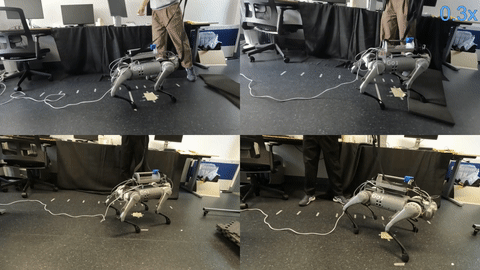
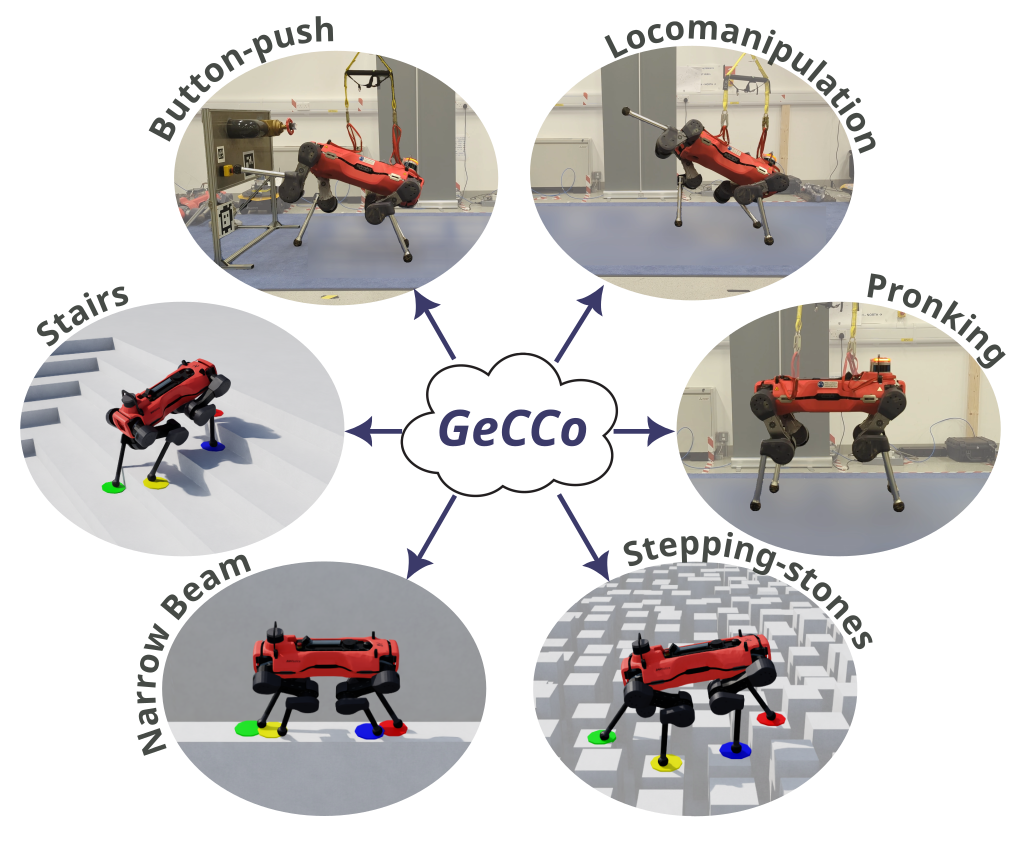
GeCCo -- a Generalist Contact-Conditioned Policy for Loco-Manipulation Skills on Legged Robots (2025)
Vassil Atanassov, Wanming Yu, Siddhant Gangapurwala, James Wilson, Ioannis Havoutis
Preprint
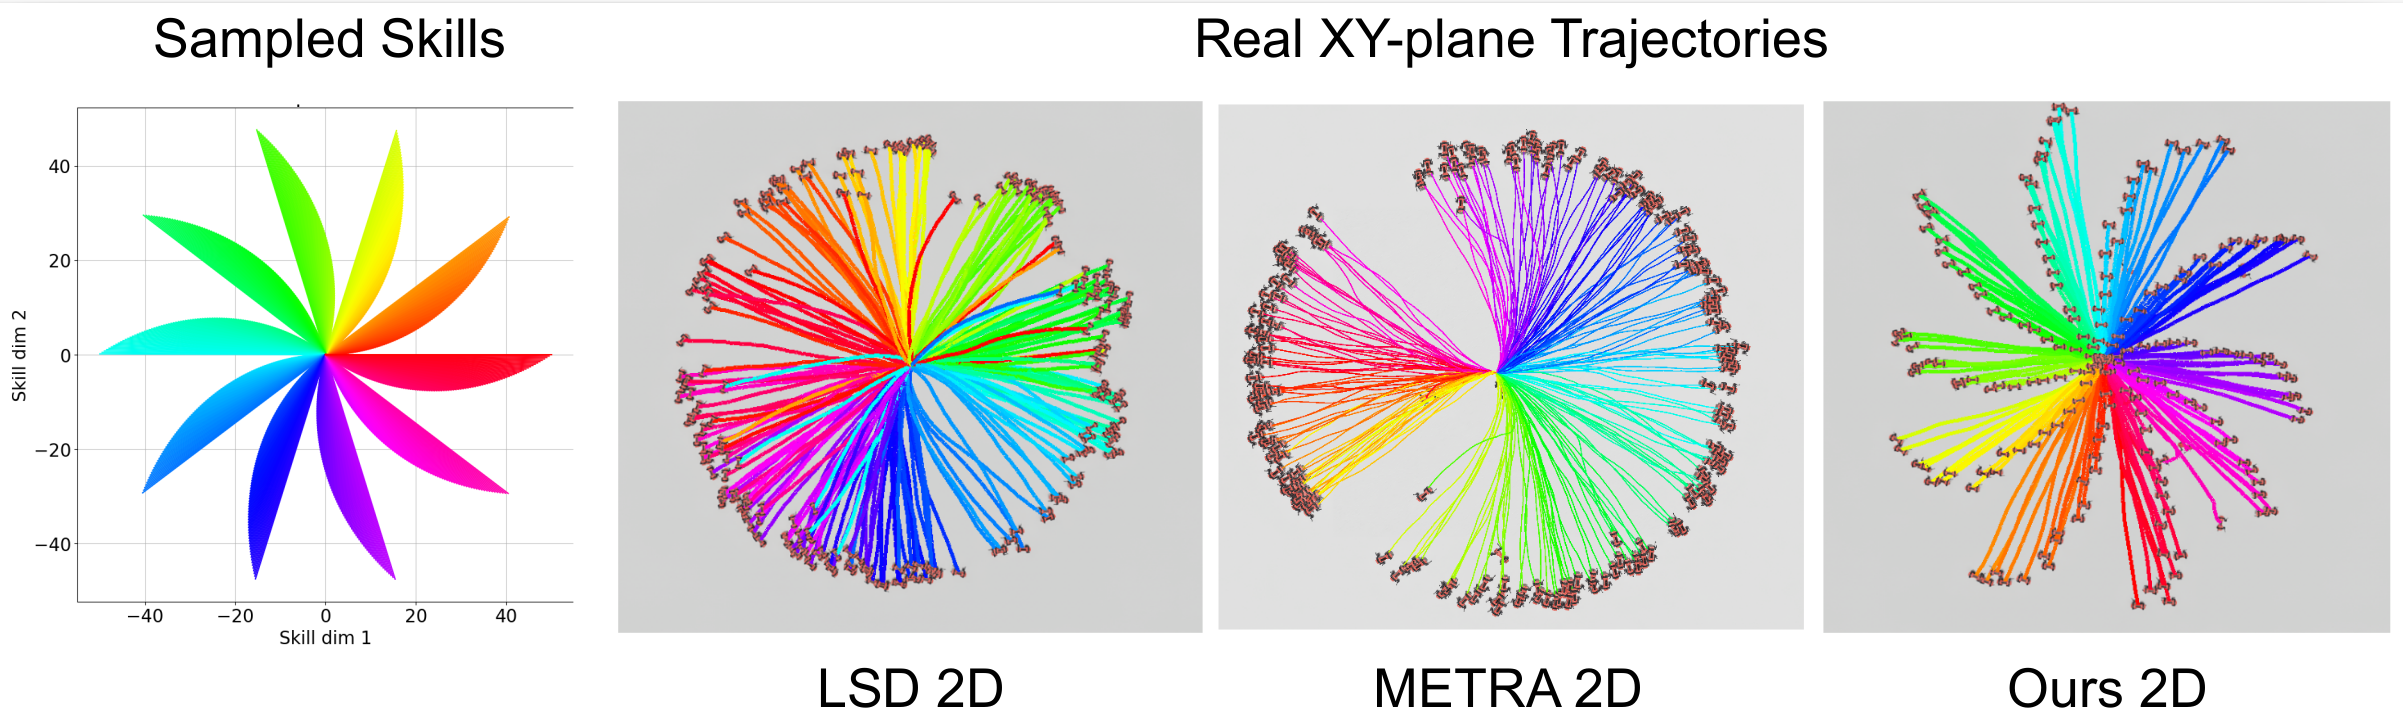
Constrained Skill Discovery: Quadruped Locomotion with Unsupervised Reinforcement Learning (2025)
Vassil Atanassov, Wanming Yu, Alexander L. Mitchell, Mark N. Finean and Ioannis Havoutis
Preprint
On-the-Fly Jumping with Soft Landing: Leveraging Trajectory Optimization and Behavior Cloning (2025)
Edoardo Panichi, Jiatao Ding, Vassil Atanassov, Peiyu Yang, Jens Kober, Wei Pan, Cosimo Della Santina
IEEE/ASME Transactions on Mechatronics
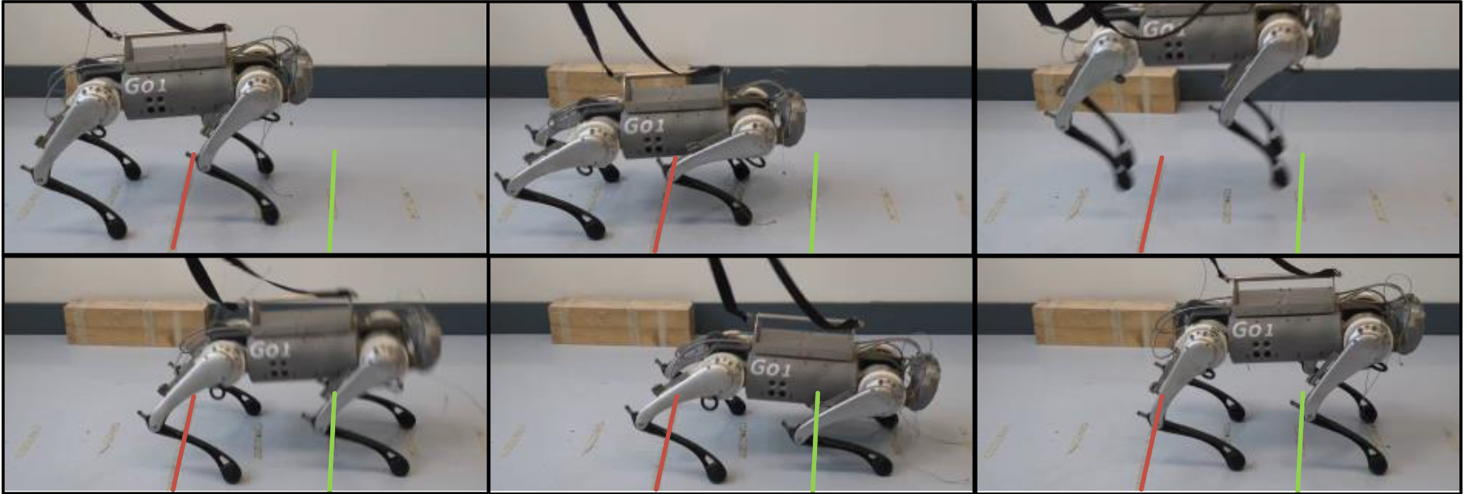
Curriculum-based Reinforcement Learning for Quadrupedal Jumping: A Reference-free Design (2024)
Vassil Atanassov, Jiatao Ding, Jens Kober, Ioannis Havoutis and Cosimo Della Santina
IEEE Robotics and Automation Magazine
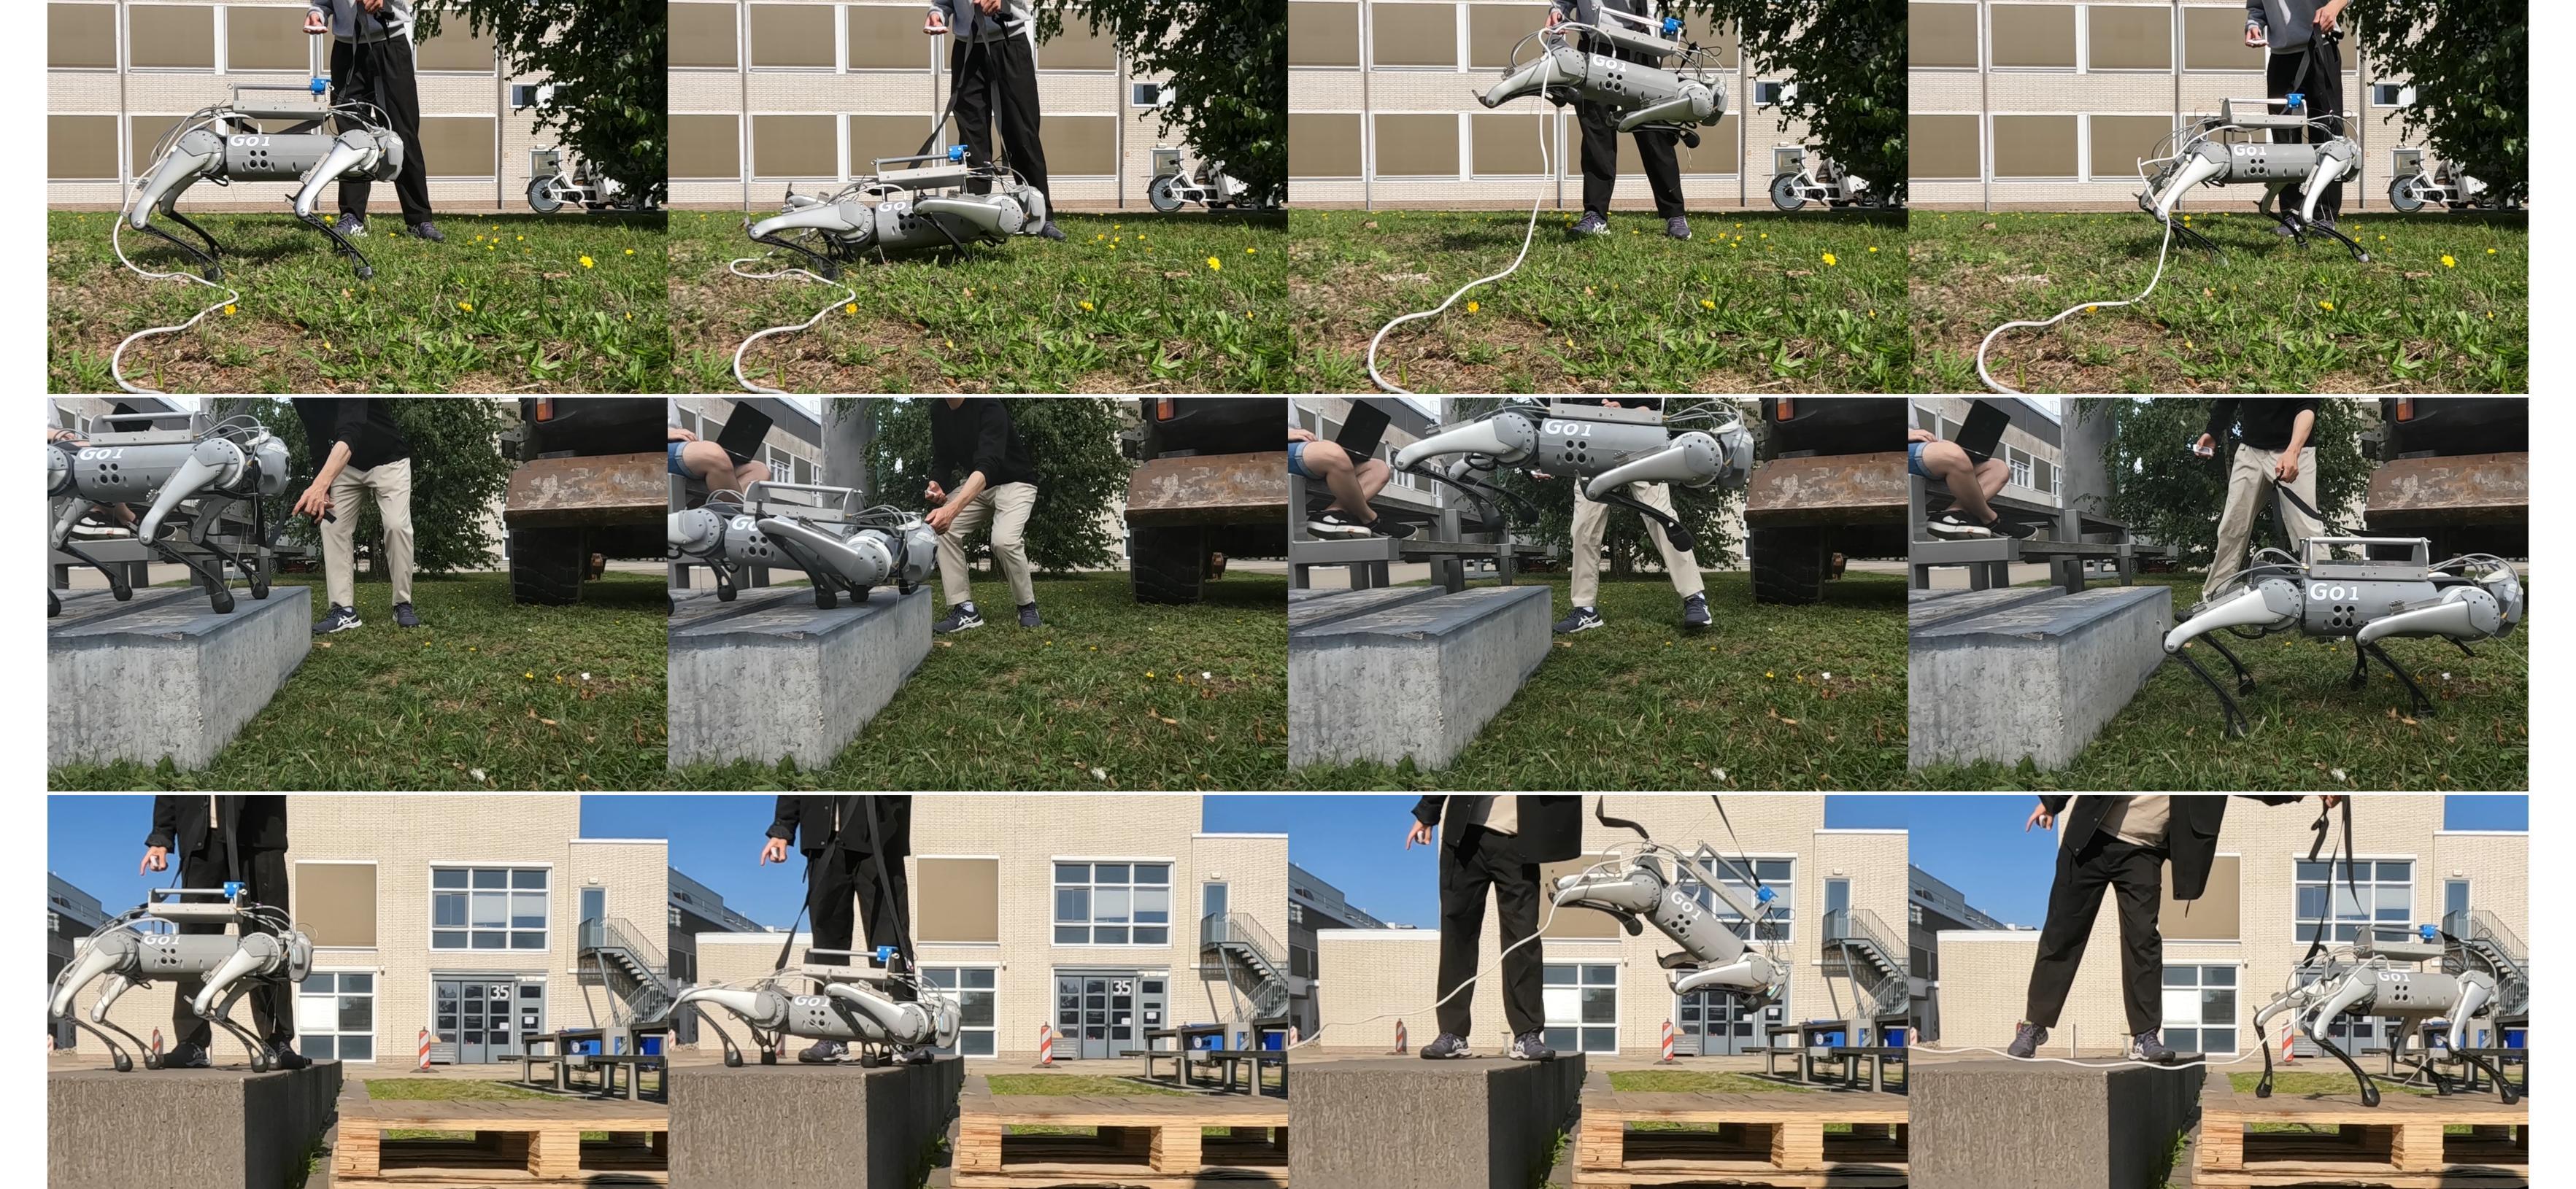
Robust Quadrupedal Jumping with Impact-Aware Landing: Exploiting Parallel Elasticity (2024)
Jiatao Ding, Vassil Atanassov, Edoardo Panichi, Jens Kober and Cosimo Della Santina
IEEE Transactions on Robotics
DOI
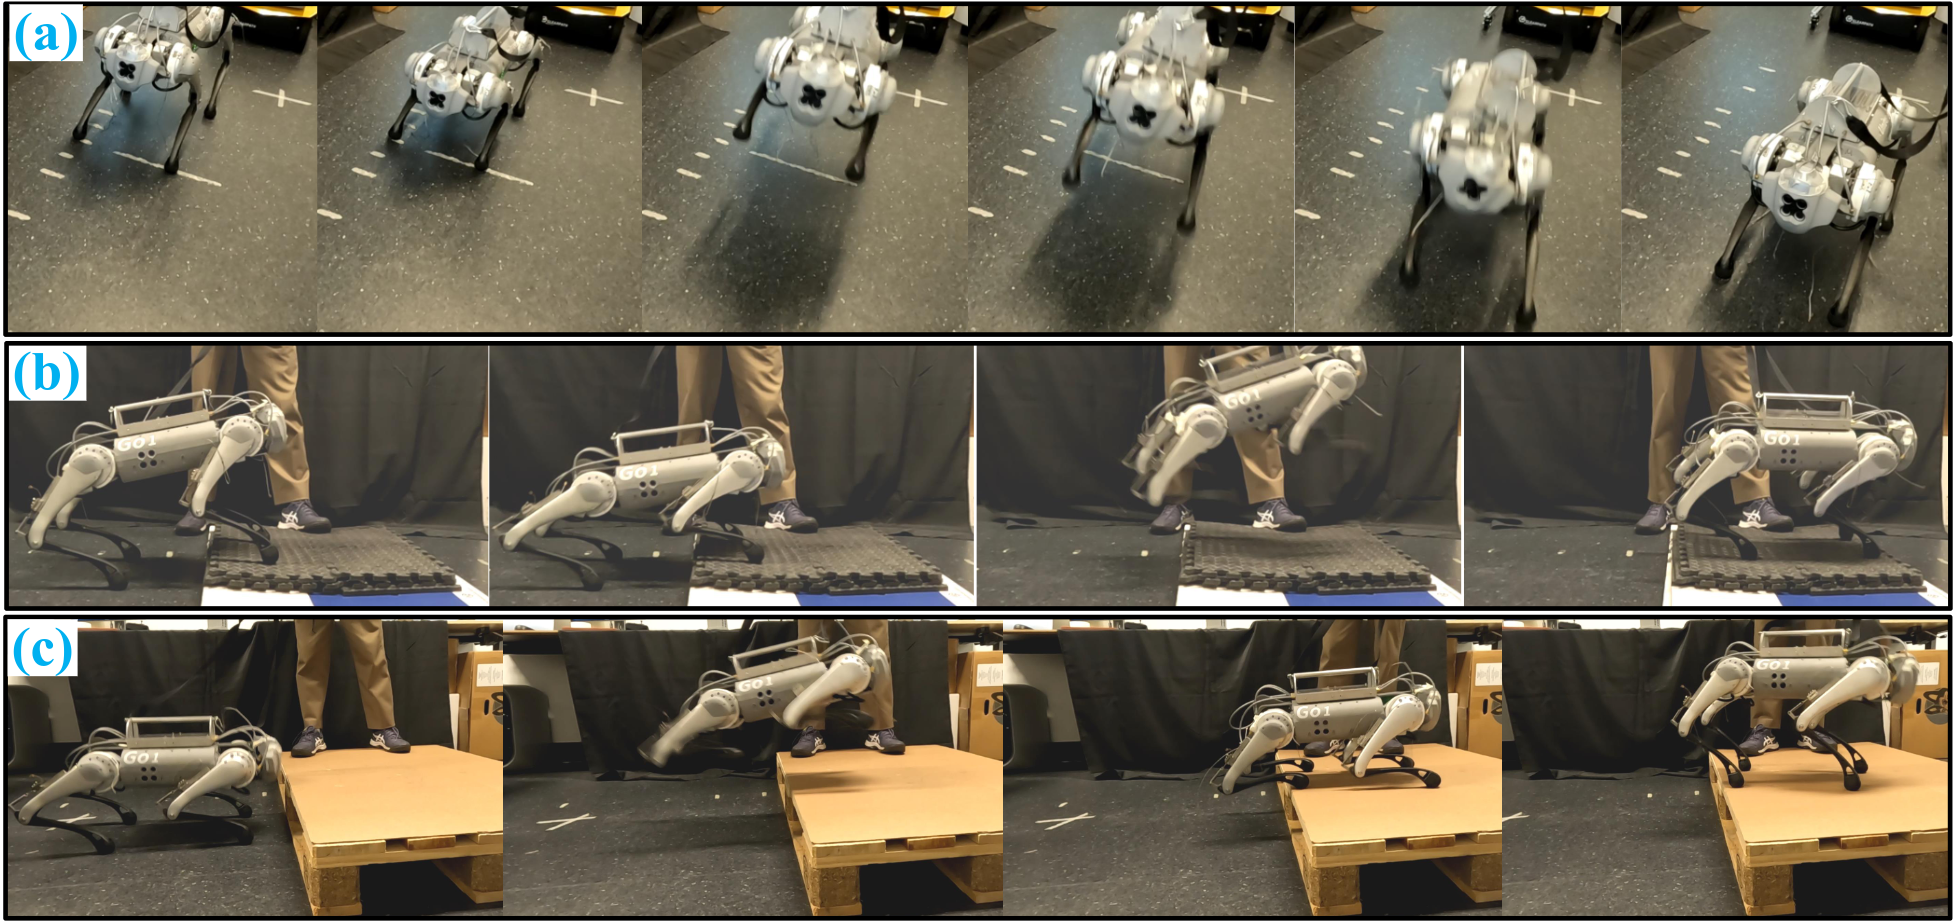
Quadrupedal Locomotion With Parallel Compliance: E-Go Design, Modeling, and Control (2024)
Jiatao Ding, Perry Posthoorn, Vassil Atanassov, Fabio Boekel, Jens Kober and Cosimo Della Santina
IEEE/ASME Transactions on Mechatronics
DOI